

Lub hauv paus ntsiab lus ua haujlwm ntawm AC motors
Jan 04, 2026
AC lub cev muaj zog yog ib qho khoom siv uas hloov hluav taws xob los ntawm kev hloov tam sim no rau hauv lub zog siv tshuab. Nws feem ntau yog siv los ntawm electromagnetic winding los yog faib stator winding siv los tsim ib qho chaw sib nqus, nrog rau lub rotating armature lossis rotor. Lub cev muaj zog ua haujlwm raws li lub hauv paus ntsiab lus uas tam sim no - nqa coil ntsib lub zog hauv qhov sib nqus, ua rau nws tig. AC motors tau muab faib ua ob hom: synchronous AC motors thiab induction motors [1].
Lub stator windings ntawm peb -theem AC lub cev muaj zog yog qhov tseem ceeb peb lub kauj sib nrug ntawm 120 degrees sib nrug, txuas rau hauv ib qho delta lossis lub hnub qub teeb tsa. Thaum peb -theem tam sim no raug siv, ib qho chaw sib nqus yog tsim nyob rau hauv txhua lub kauj, thiab kev sib xyaw ntawm peb daim teb no ua rau muaj qhov sib nqus sib nqus.
AC motors muaj xws li stator thiab rotor, thiab muab faib ua ob hom: synchronous AC motors thiab induction motors. Ob hom motors tsim ib qho kev sib nqus sib nqus los ntawm kev sib hloov tam sim no los ntawm stator winding, tab sis lub rotor winding ntawm synchronous AC motors feem ntau yuav tsum muaj qhov ncaj qha tam sim no (excitation tam sim no) los ntawm exciter; Induction motors, ntawm qhov tod tes, tsis xav tau tam sim no kom dhau los ntawm rotor winding.

Lub stator winding ntawm peb -theem AC lub cev muaj zog yog tsim los ntawm peb lub kauj sib nrug ntawm 120 degrees sib nrug los ntawm ib leeg, txuas rau hauv daim duab peb sab lossis lub hnub qub. Thaum peb -theem tam sim no raug siv, ib qho chaw sib nqus yog tsim nyob rau hauv txhua lub kauj, thiab peb qhov chaw sib nqus no ua ke los ua ib qho chaw sib nqus sib nqus. Qhov tam sim no ua tiav tag nrho kev co, thiab cov rotating magnetic teb rotates raws nraim ib zaug. Yog li ntawd, tus naj npawb ntawm revolutions ib feeb ntawm rotating magnetic teb yog N=60f. Hauv cov qauv, f yog lub zog zaus.
AC motors tuaj yeem muab faib ua synchronous motors thiab asynchronous motors (tseem hu ua asynchronous motors) raws li qhov ceev ntawm rotor tig. Txawm hais tias qhov loj me me, lub rotor ceev ntawm lub tshuab synchronous yog ib txwm zoo ib yam li qhov nrawm ntawm qhov sib nqus sib nqus, yog li qhov ceev no hu ua synchronous ceev. Raws li tau hais los saum no, nws tsuas yog nyob ntawm qhov zaus ntawm cov khoom siv fais fab. Qhov ceev ntawm asynchronous motors tsis tas li, nws nyob ntawm qhov loj ntawm lub load thiab lub hwj huam mov voltage. Muaj ob hom peb -theem asynchronous motors: cov tsis muaj rectifiers thiab cov uas muaj rectifiers. Feem ntau ntawm asynchronous motors siv nyob rau hauv cov ntaub ntawv siv tau yog induction motors tsis muaj rectifiers (txawm hais tias thaum uas tig mus thiab series peb -theem asynchronous rectifier motors muaj qhov zoo ntawm adjustable ceev tshaj ib tug loj ntau yam thiab siab zog factor), thiab lawv ceev yog ib txwm qis dua lub synchronous ceev.
Lub hom phiaj tseem ceeb
Kev ua haujlwm ntawm AC lub cev muaj zog yog siab, tsis muaj pa taws, tsw ntxhiab, ib puag ncig muaj kuab paug, thiab suab nrov tsawg. Vim nws cov txiaj ntsig zoo, nws tau siv dav hauv ntau yam xws li kev lag luam thiab kev ua liaj ua teb, kev thauj mus los, kev tiv thaiv hauv tebchaws, kev lag luam thiab khoom siv hauv tsev, khoom siv kho mob, thiab lwm yam.
Txoj cai ua haujlwm
Induction lub cev muaj zog, tseem hu ua asynchronous lub cev muaj zog, hais txog lub rotor tau muab tso rau hauv qhov sib nqus sib nqus thiab tau txais lub zog sib hloov raws li qhov kev txiav txim ntawm lub rotor magnetic teb, ua rau lub rotor tig.
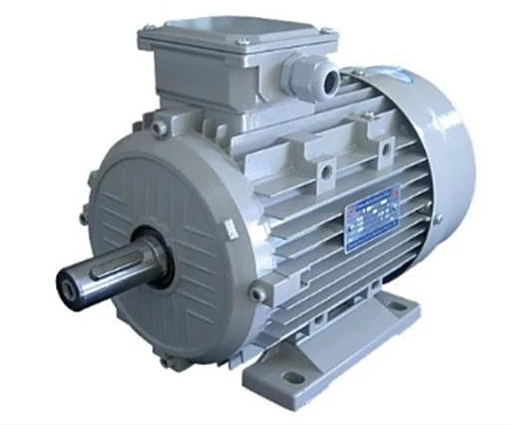
Cov tsos thiab cov qauv sab hauv ntawm lub cev muaj zog induction. Lub rotor yog ib tug rotatable conductor, feem ntau nyob rau hauv cov duab ntawm ib tug squirrel tawb. Lub stator yog qhov tsis tig ntawm lub tshuab hluav taws xob, uas nws lub luag haujlwm tseem ceeb yog los tsim kom muaj qhov sib nqus sib nqus. Rotating magnetic teb tsis ua tiav los ntawm kev siv tshuab. Tab sis qhov hloov pauv tam sim no yog siv rau ob peb khub ntawm electromagnets, ua rau lawv cov khoom sib nqus ntawm lub voj voog hloov, yog li sib npaug rau qhov sib nqus sib nqus. Hom lub cev muaj zog no tsis muaj cov txhuam hniav lossis cov nplhaib sib dhos zoo li DC motors. Nyob ntawm seb hom AC fais fab siv, muaj ib zaug -theem motors thiab peb-theem motors. Tib theem motors yog siv rau hauv cov khoom siv xws li tshuab ntxhua khaub ncaws thiab hluav taws xob kiv cua; Peb theem hluav taws xob lub cev muaj zog yog siv los ua cov khoom siv hluav taws xob hauv cov chaw tsim khoom. Los ntawm cov kev txheeb ze ntawm cov rotating magnetic teb generated los ntawm lub stator (nrog ib synchronous ceev ntawm n1) thiab lub rotor winding, lub rotor winding txiav cov magnetic induction kab thiab generates induced electromotive quab yuam, li no generating induced tam sim no nyob rau hauv lub rotor winding. Lub induced tam sim no nyob rau hauv lub rotor winding interacts nrog lub magnetic teb los tsim electromagnetic torque, ua rau lub rotor tig. Raws li lub rotor ceev maj mam nce mus rau synchronous ceev, induced tam sim no maj mam txo, thiab generated electromagnetic torque kuj txo raws li. Thaum lub asynchronous lub cev muaj zog ua haujlwm nyob rau hauv lub xeev lub cev muaj zog, lub rotor ceev yog qis dua lub synchronous ceev. Los piav txog qhov sib txawv ntawm rotor ceev n thiab synchronous ceev n1, ib qho piv txwv yog qhia
Tswj lub tswv yim
Nrog rau kev tsim hluav taws xob hluav taws xob thev naus laus zis, microelectronics thev naus laus zis, digital tswj thev naus laus zis, thiab kev tswj kev xav, cov yam ntxwv zoo li qub thiab zoo li qub ntawm AC tsav tshuab tuaj yeem sib piv rau DC tsav tshuab. AC tsav tshuab tau siv dav, thiab kev hloov ntawm DC tsav los ntawm AC tsav tau maj mam dhau los ua qhov tseeb.
Vim lub fact tias AC motors yog inherently complex khoom nrog nonlinearity, multi variables, muaj zog coupling, lub sij hawm - txawv tsis, thiab loj cuam tshuam, lawv cov kev tswj tau zoo yeej ib txwm yog ib tug kub kev tshawb fawb cov ntsiab lus nyob rau hauv lub domestic thiab txawv teb chaws, thiab ntau yam kev tswj cov tswv yim thiab txoj kev tau raug npaj. Ntawm lawv, classical linear tswj tsis tuaj yeem kov yeej kev cuam tshuam ntawm kev thauj khoom, loj - teev kev hloov pauv hauv cov qauv tsis, thiab cov yam tsis sib xws, ua rau muaj kev tswj xyuas qis; Vector tswj thiab tswj torque ncaj qha kuj muaj qee qhov teeb meem: nyob rau hauv xyoo tas los no, nrog rau kev txhim kho ntawm kev tswj niaj hnub thiab kev txawj ntse tswj txoj kev xav, kev tswj hwm qib siab tau siv rau AC lub cev muaj zog tswj thiab tau ua tiav qee qhov txiaj ntsig [2].
Steady xeev qauv tswj txoj kev
Cov feem ntau siv khov kho- xeev cov qauv tswj cov txheej txheem suav nrog qhib- lub voj voog tsis tu ncua v/f piv tswj (ie voltage / zaus= tsis tu ncua) thiab kaw - voj voj voog ntau zaus tswj.
(1) Tsis tu ncua voltage zaus piv tswj
Txoj kev no yog ib qho qhib - txoj kev tswj lub voj uas pib los ntawm hom kev tswj hwm ntawm qhov sib txawv ntawm qhov voltage thiab zaus hloov dua siab tshiab thiab tsis suav nrog kev tawm tswv yim ceev. Vim qhov tseeb tias qis dua qhov ntsuas zaus, yog tias qhov hluav taws xob tseem nyob tas li thiab tsuas yog qhov zaus raug txo, cov huab cua sib txawv ntawm qhov sib txawv yuav loj dhau, ua rau sib nqus saturation thiab, nyob rau hauv cov xwm txheej hnyav, hlawv tawm lub cev muaj zog. Txhawm rau kom tswj tau qhov tsis tu ncua ntawm huab cua sib nqus sib nqus flux, qhov tsis tu ncua ntawm qhov cuam tshuam rau qhov zaus yog siv los tswj.

Tej Faults
AC motors nquag ua haujlwm tsis zoo thaum lub sijhawm ua haujlwm vim kev sib txhuam, kev vibration, rwb thaiv tsev laus, thiab lwm yam. Yog tias cov kev ua txhaum no raug kuaj xyuas, tshawb pom, thiab tshem tawm raws sijhawm, lawv tuaj yeem tiv thaiv kom tsis txhob muaj xwm txheej tshwm sim.
Kev soj ntsuam yuam kev
1. Mloog lub suab thiab ua tib zoo txheeb xyuas qhov yuam kev. Thaum lub sijhawm ua haujlwm ntawm AC asynchronous lub cev muaj zog, yog tias pom lub suab "buzzing" tsis muaj qhov hloov pauv, nws yog lub suab qub. Yog tias lub suab ntxhib thiab muaj lub suab "buzzing" lossis "hissing", nws yog qhov ua ntej rau qhov txhaum. Cov laj thawj hauv qab no yuav tsum xav txog:
(l) Kev vibration thiab hloov pauv kub ntawm lub cev muaj zog nrog xoob hlau tub ntxhais thaum lub sijhawm ua haujlwm tuaj yeem ua rau deformation ntawm kev txhim kho bolts ntawm cov tub ntxhais hlau, uas ua rau cov nplooj ntawv silicon hlau xoob thiab ua rau lub suab nrov nrov.
(2) Lub suab tsim los ntawm kev sib hloov ntawm lub rotor, uas yog tsim los ntawm lub kiv cua txias, yog lub suab "wuwu". Yog hais tias muaj lub suab "dongdong" zoo li khob lub nruas, nws yog tshwm sim los ntawm kev xoob ntawm qhov haum ntawm lub rotor hlau core thiab ncej vim lub acceleration torque ntawm lub cev muaj zog thaum pib, nres, thim rov qab braking thiab lwm yam hloov pauv ceev. Cov mob me tuaj yeem siv txuas ntxiv mus, thaum cov mob hnyav tuaj yeem raug tshem tawm rau kev tshuaj xyuas thiab kho.
(3) Thaum lub sijhawm ua haujlwm ntawm cov kabmob suab nrov, nws yog qhov yuav tsum tau ua tib zoo saib xyuas cov kev hloov ntawm cov kabmob suab. Los ntawm kov ib kawg ntawm tus ntsia thawv ntsia hlau ntawm lub hau npog thiab lwm qhov kawg ntawm lub pob ntseg, lub suab hloov hauv lub cev tuaj yeem hnov. Qhov sib txawv thiab qhov yuam kev muaj lub suab sib txawv. Lub suab ntawm "creaking" yog tshwm sim los ntawm kev txav tsis tu ncua ntawm rab phom dov hauv cov kabmob, uas cuam tshuam nrog kev tshem tawm ntawm cov kabmob thiab lub xeev ntawm cov roj lubricating. Lub suab "sizzling" yog lub suab sib txhuam hlau, feem ntau tshwm sim los ntawm qhov tsis muaj roj hauv cov kabmob vim hnav. Cov kabmob yuav tsum tau disassembled thiab lubricated nrog roj, thiab lwm yam.
2. Siv qhov hnov tsw ntxhiab los soj ntsuam tias lub cev muaj zog tsis muaj ntxhiab tsw thaum lub sijhawm ua haujlwm. Yog tias koj hnov tsw tsw, nws yog ib qho teeb meem txhaum cai, xws li burnt tsw, uas yog tawm los ntawm rwb thaiv tsev grilling thiab muaj peev xwm txawm haus luam yeeb thaum lub cev muaj zog kub nce; Yog tias muaj roj tsw qab, nws feem ntau yog vim tsis muaj roj nyob hauv cov kabmob, thiab cov ntxhiab tsw tshwm sim los ntawm cov evaporation ntawm cov roj thiab cov pa roj thaum mus txog lub xeev sib tsoo qhuav.
3. Siv lub tactile rhiab heev los kuaj xyuas qhov txhaum. Los ntawm kov lub casing ntawm lub TV nrog koj txhais tes, koj tuaj yeem txiav txim siab qhov kub thiab txias. Yog tias koj xav tias kub heev thiab qhov kub ntawm qhov ntsuas kub siab thaum kov lub cev muaj zog nrog koj txhais tes, koj yuav tsum xyuas qhov ua rau, xws li kev thauj khoom ntau dhau lossis qhov hluav taws xob siab, thiab tom qab ntawd kho qhov teeb meem raws li qhov ua rau.


